Tag#robotics
Tag#robotics
Highlight 1Mapping haptic gestures to swarm robots [note-0056]
Highlight 1Mapping haptic gestures to swarm robots [note-0056]
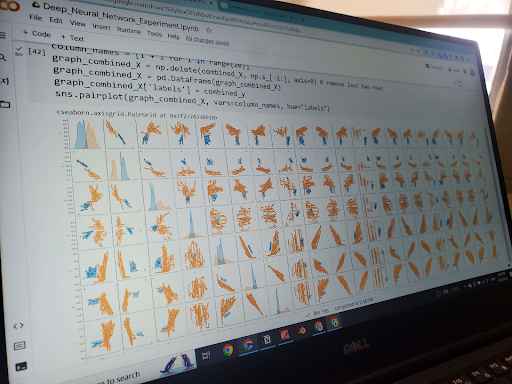
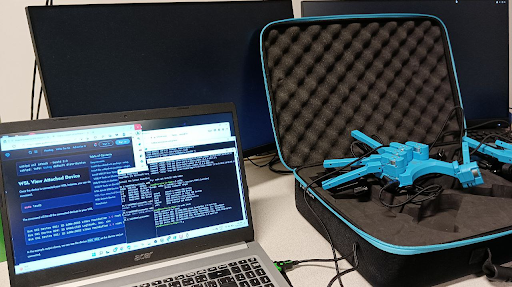
At UWaterloo ERABLab, we built a neural network that recognizes gestures of the Senseglove haptic hand and controls the motion of brushbots with Professor Gennaro Notomista. This involved learning linear algebra, some multivariable calculus, neural networks, the PyTorch framework, Linux and ROS. There was a more-than-expected amount of troubleshooting.
Note 2Reading particle swarm optimization and implementing it in Unity [note-0055]
Note 2Reading particle swarm optimization and implementing it in Unity [note-0055]
A friend @0xredJ has found this helpful and I decided to share my notes!
A time ago, Feynman noticed the ants in his kitchen would form trails to food sources. So, he enticed the ants with a sugar cube and disrupted them by drawing coloured trails on the ground. The ants didn't care. Then he folded a paper bridge and waited for ants to step on them. Then he ferried the ants from one place to another. At the new location, the ants would initially be lost but over time form a nearly shortest path again.
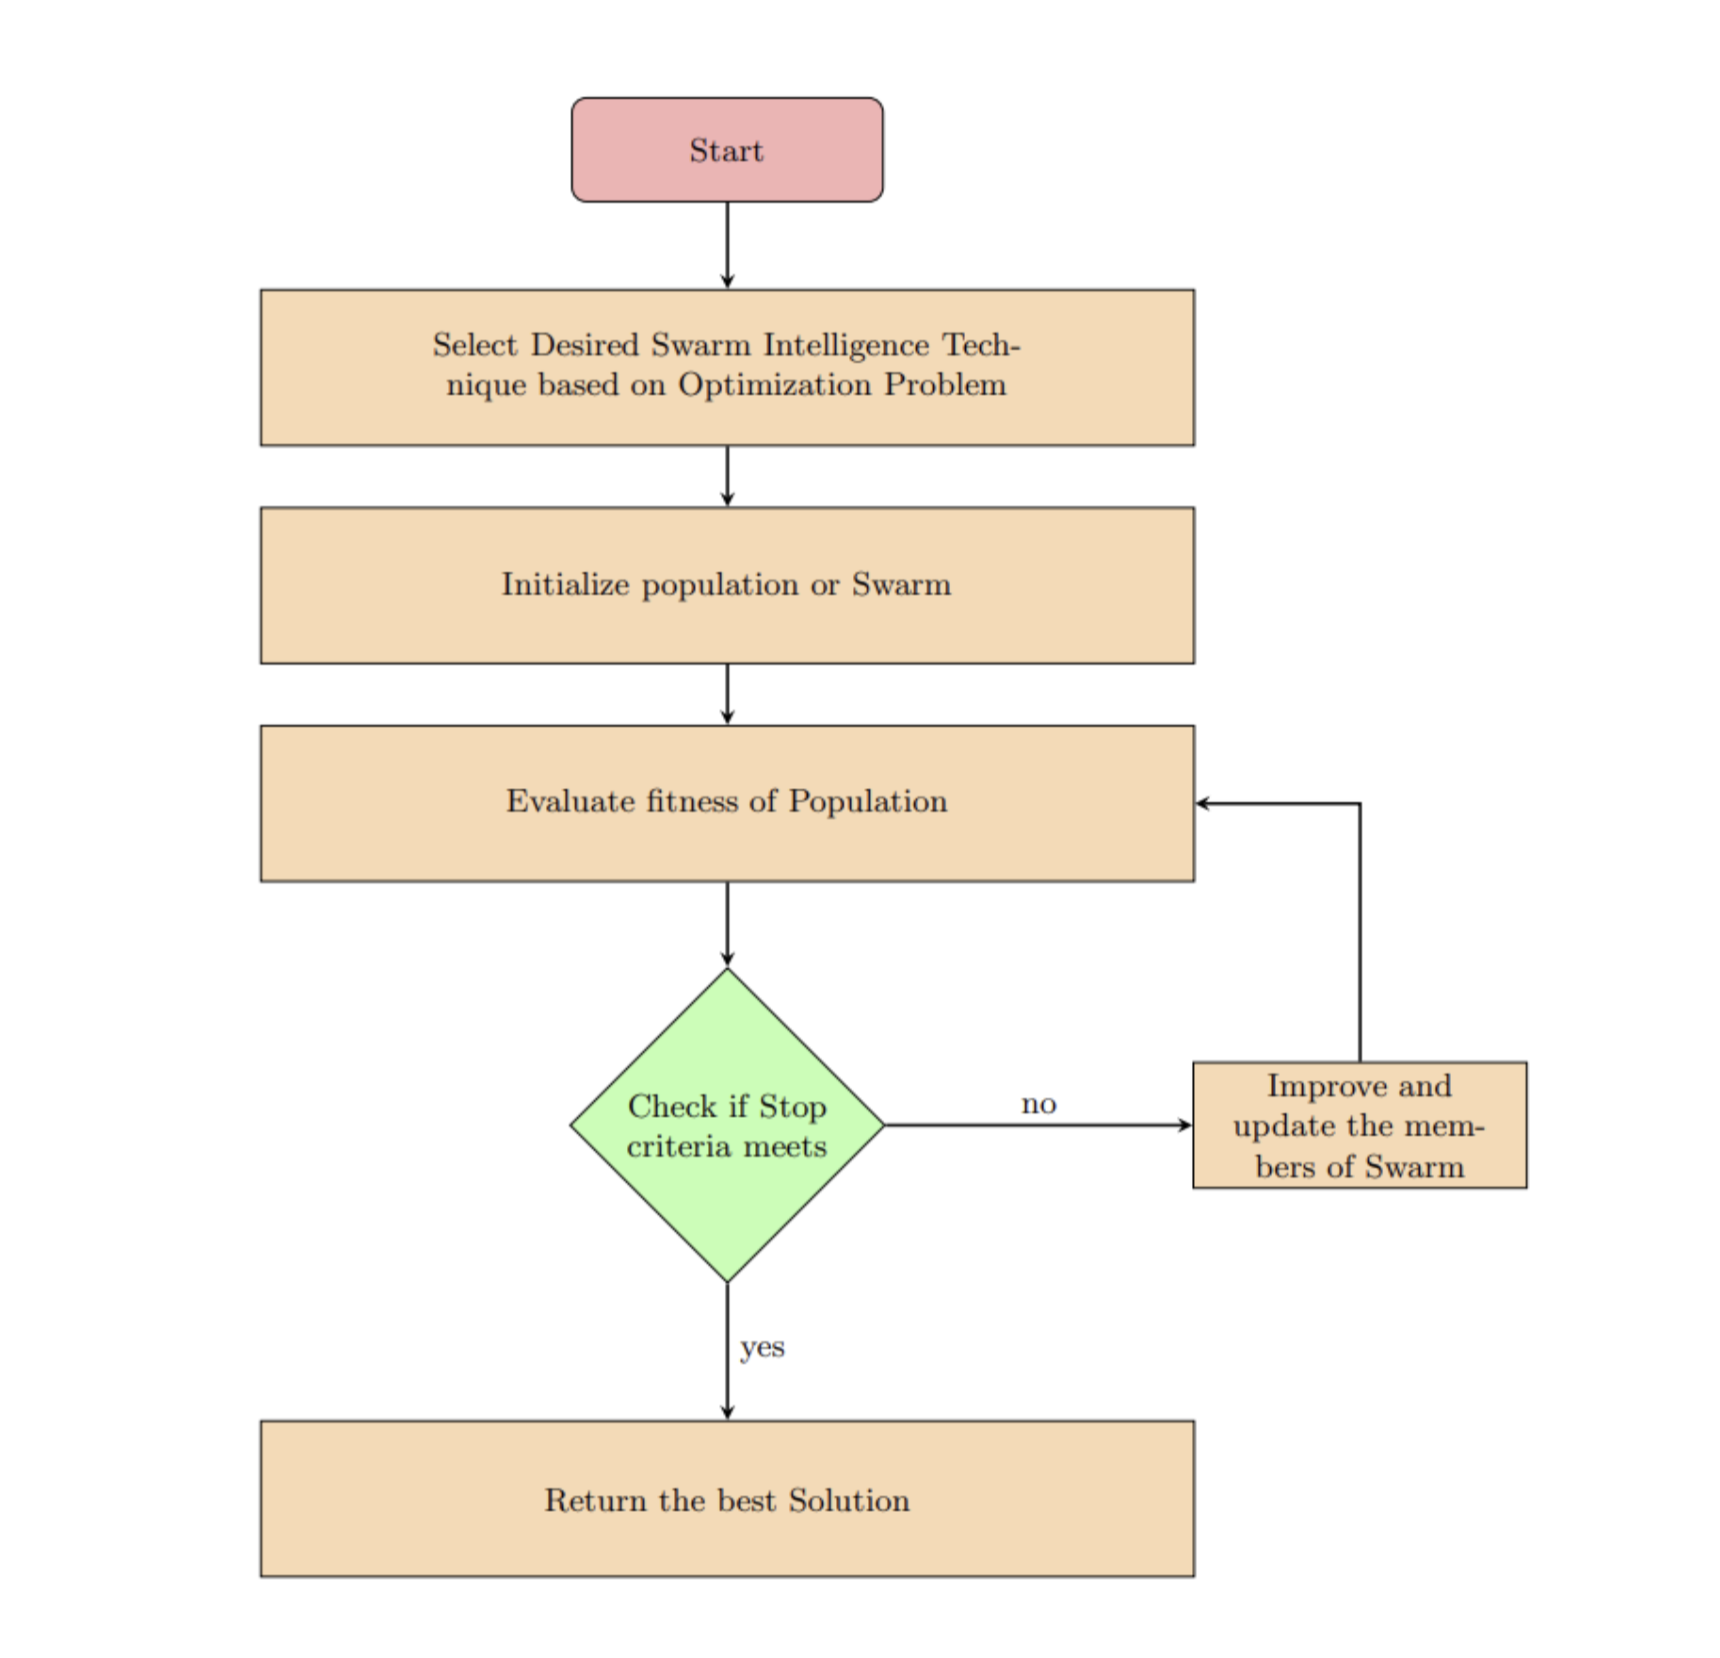
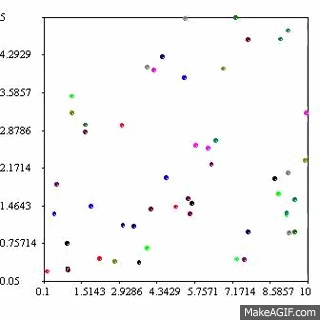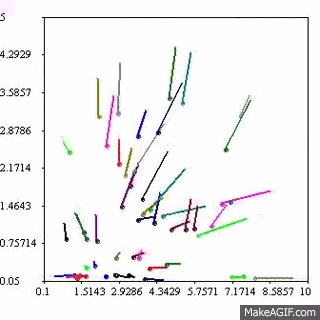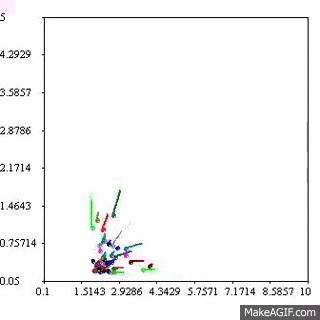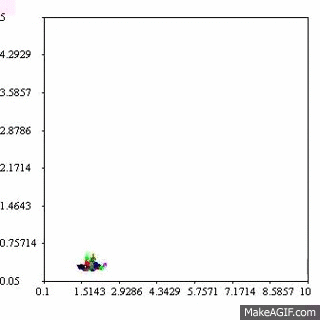
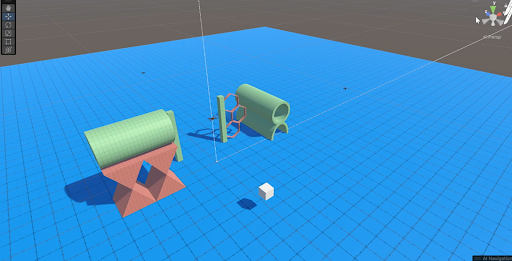
This... indirectly foreshadowed the development of Ant Colony Optimization and many more that describe the social behaviour of insects and in nature toward a target. Particle Swarm Optimization is a famous one, let's see a video (plugging my code demo!).
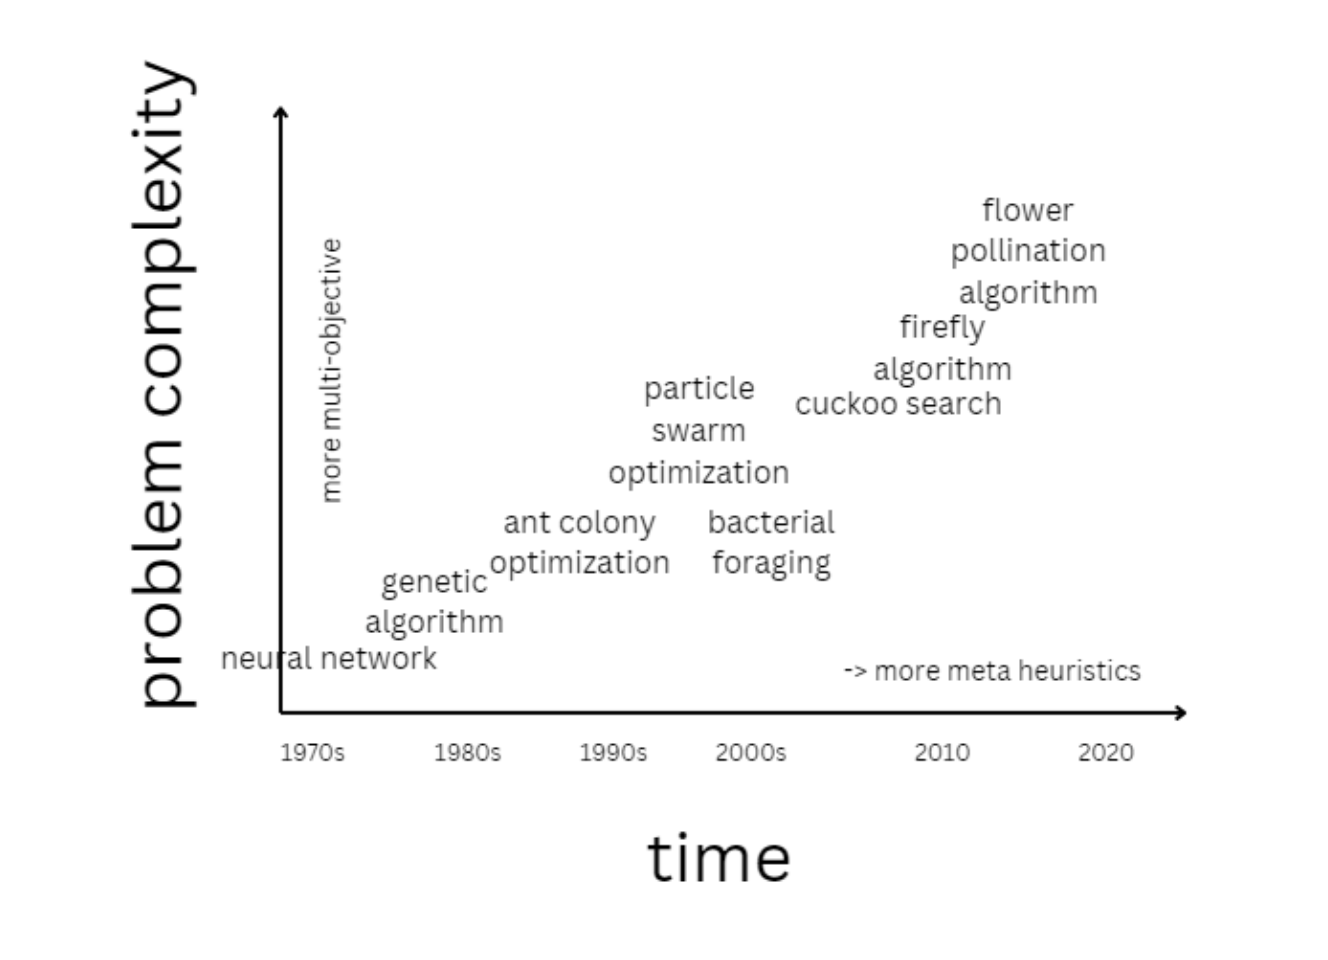
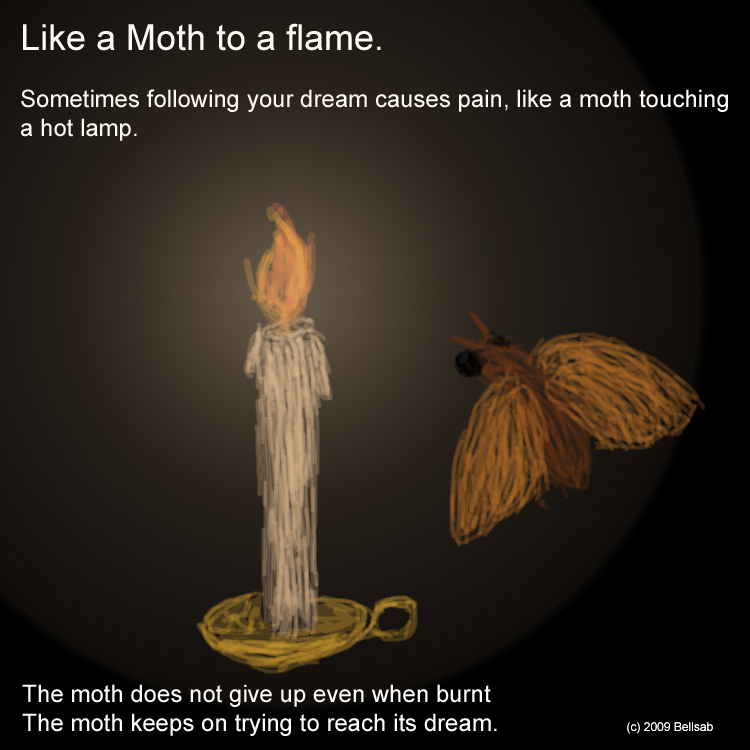
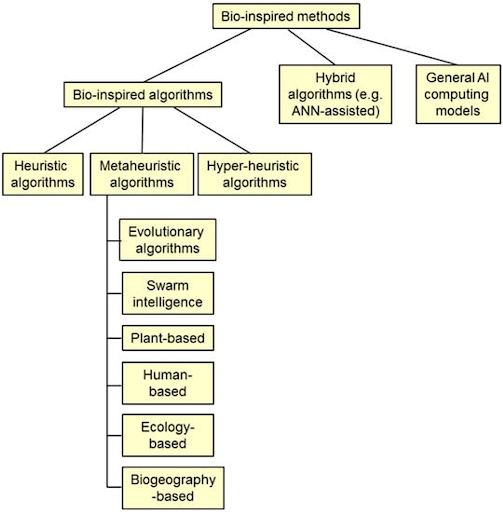
Of course, there are also bacteria, fireflies, cuckoos, flower polllination and living neurons which served as inspirations. You can see the development of these algorithms through time.
 Assumptions
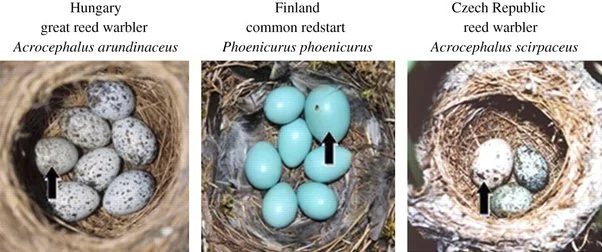
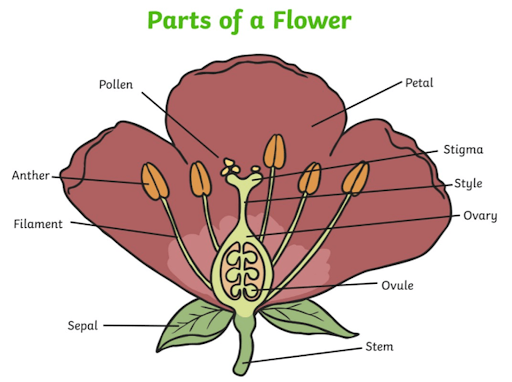 Forms of pollination:
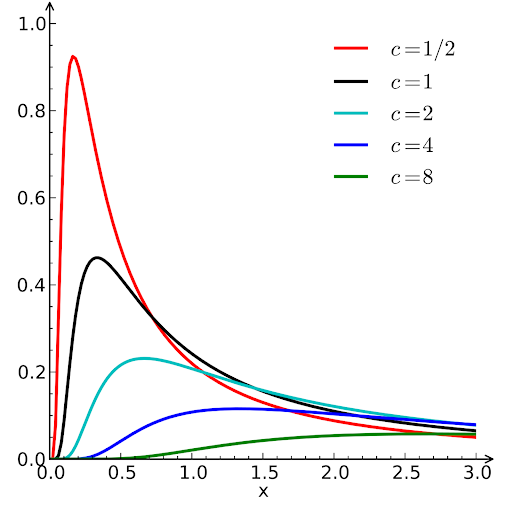
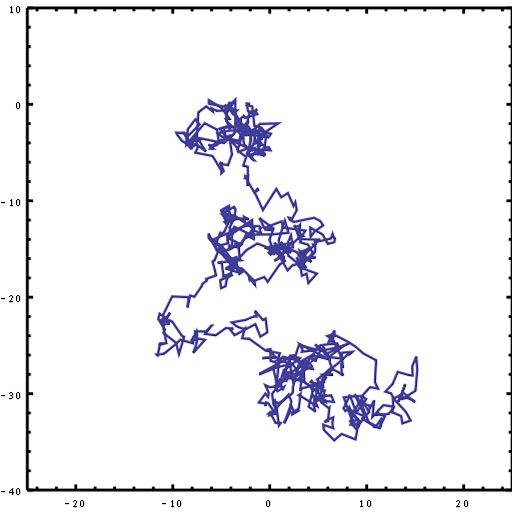 The area under the curve sums to one. So, we model distances using Levy flights to mimic the behavior of pollinators traveling between
flowers.
Note 3T-posing on humanoid robots [note-0025]
Note 3T-posing on humanoid robots [note-0025]
It was really difficult to work with humanoid robots given numerous servo motor incongruences during calibration. So we threw a hail Mary and just told the robot to go to T-pose on demand, given webcam data. Connect to robot, program fixed points, figure out centre of mass and bounds while playing back pose trajectories.
Note 4Chem-0 [note-0008]
Note 4Chem-0 [note-0008]
Robot lab bench setup, which did not work yet because calibration (to be updated)
Lab bench:


