Mapping haptic gestures to swarm robots [note-0056]
Mapping haptic gestures to swarm robots [note-0056]
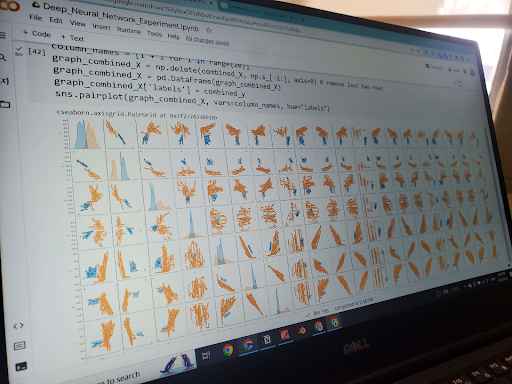
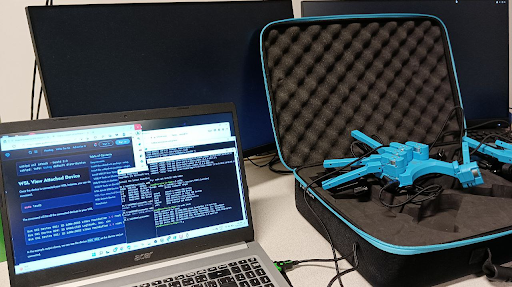
At UWaterloo ERABLab, we built a neural network that recognizes gestures of the Senseglove haptic hand and controls the motion of brushbots with Professor Gennaro Notomista. This involved learning linear algebra, some multivariable calculus, neural networks, the PyTorch framework, Linux and ROS. There was a more-than-expected amount of troubleshooting.